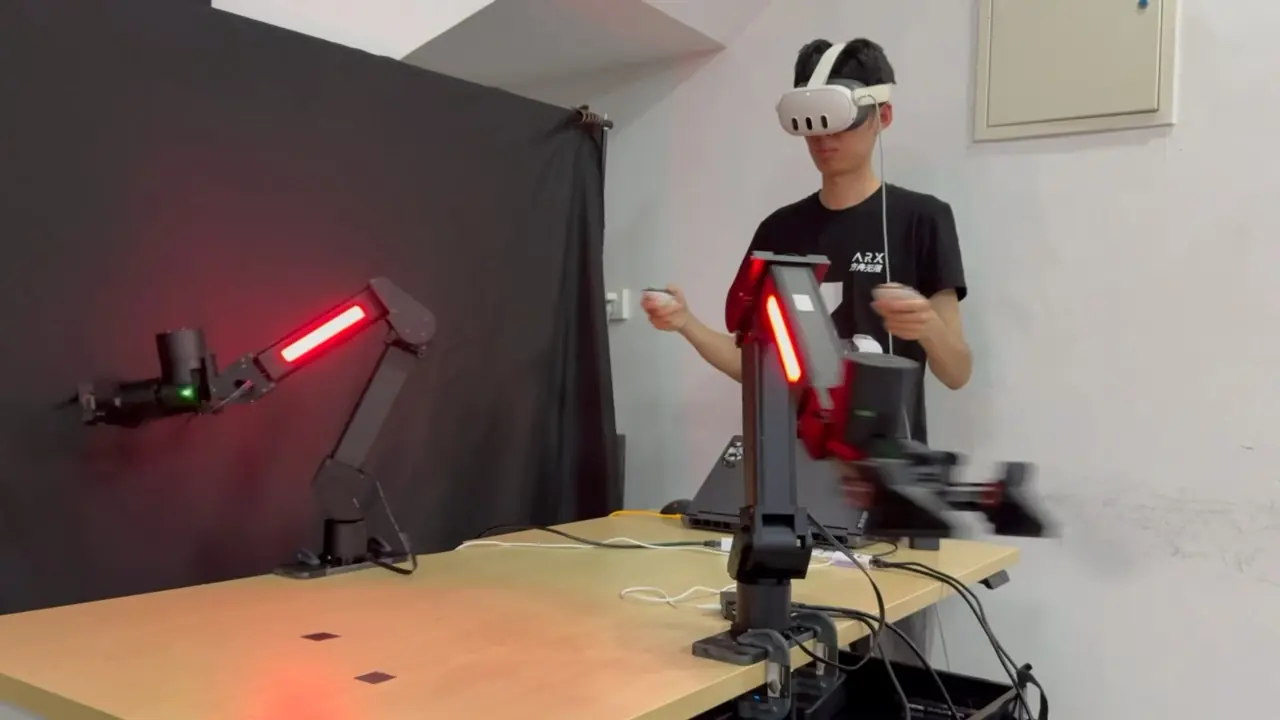
Short answer: ARX lists 21 published projects that were built on its hardware, including π0, π0.5, π0.7, RDT, ViA, Motus and Xiaomi-Robotics-0. Four more public projects, EgoVerse, RoboTwin 2.0, UMI and UVA, name ARX arms in their papers or code. Together they cover foundation models, world models, human-to-robot transfer, reinforcement learning and benchmarks.
How we checked each project
There are two kinds of evidence:
- Named in the project's own material. The paper, project page or code names ARX hardware. Examples: π0's training mixture lists "Bimanual ARX"; Motus ran its real-world experiments on AC-One; ViA thanks ARX for its robot hardware.
- Listed by ARX. The project appears in ARX's list of research built on its platform at arx-x.com, and the project page does not name the hardware.
The research page marks which kind applies to each entry.
Foundation models and VLAs
| Project |
Year |
What it is |
Evidence |
| π0 |
2024 |
Physical Intelligence's generalist vision-language-action flow model |
Training mixture lists "Bimanual ARX" |
| RDT |
2024 |
1.2B-parameter diffusion model for bimanual manipulation, Tsinghua |
Listed by ARX |
| π0.5 |
2025 |
VLA aimed at open-world generalization |
Listed by ARX |
| InternVLA |
2025 |
Policy unifying vision-language understanding, visual foresight and action |
Listed by ARX |
| Xiaomi-Robotics-0 |
2026 |
4.7B-parameter VLA from Xiaomi |
Listed by ARX |
| π0.7 |
2026 |
Physical Intelligence's April 2026 model |
Listed by ARX |
| LingBot-VA 2.0 |
2026 |
Video-action model from Robbyant (Ant Group) |
Listed by ARX |
| Xiaomi-Robotics-1 |
2026 |
Foundation model pre-trained on 100K+ hours of UMI data |
Listed by ARX |
World models and video
| Project |
Year |
What it is |
Evidence |
| Vidar |
2025 |
Video diffusion for bimanual manipulation |
Listed by ARX |
| Motus |
2025 |
Unified latent-action world model, Tsinghua and partners |
Real-world experiments on AC-One |
| Xiaomi-Robotics-U0 |
2026 |
38B world foundation model |
Listed by ARX |
Human data and human-to-robot transfer
| Project |
Year |
What it is |
Evidence |
| UMI |
2024 |
Handheld grippers for in-the-wild demonstrations |
ARX deployment code listed in arx5-sdk |
| Human to Robot |
2025 |
Physical Intelligence research on learning from human data |
Listed by ARX |
| SIM1 |
2026 |
Cloth simulator that turns about 200 human demos into training data |
Listed by ARX |
| EgoVerse |
2026 |
1,362 hours of egocentric human demonstrations |
Both robot setups use two ARX5 arms |
| EgoWAM |
2026 |
Policies trained on egocentric video, Georgia Tech |
Listed by ARX |
Reinforcement learning and post-training
| Project |
Year |
What it is |
Evidence |
| SimpleVLA-RL |
2025 |
RL framework for VLA models |
Listed by ARX |
| π*0.6 |
2025 |
A VLA that improves from experience with RL |
Listed by ARX |
| HELP |
2026 |
Two operators supervise twelve robots during VLA post-training |
Listed by ARX |
Systems, teleoperation and benchmarks
| Project |
Year |
What it is |
Evidence |
| UMI on Legs |
2024 |
Manipulation policies on a legged robot, CoRL 2024 |
Listed as using the ARX5 SDK |
| ViA |
2025 |
Active perception for bimanual manipulation, CoRL 2025 |
Thanks ARX for the robot hardware |
| UVA |
2025 |
Unified video-action model |
ARX deployment code listed in arx5-sdk |
| RoboTwin 2.0 |
2025 |
Simulation benchmark for bimanual manipulation |
ARX-X5 is a simulated embodiment |
| RoboChallenge |
2025 |
Policies evaluated on physical robots |
Platforms include Arx5 |
| ModPack |
2026 |
Backpack teleoperation for mobile two-armed robots, Stanford |
Uses ARX5 leader arms |
What this means if you are choosing hardware
- Reproducibility. If you plan to compare against π0-style or ALOHA-style results, using arms that appear in that work removes one variable.
- Software that others have used. Stanford's arx5-sdk exists because a research lab needed it, and several of the projects above build on it.
- A benchmark path. RoboChallenge runs physical evaluations on Arx5 robots, and RoboTwin 2.0 includes ARX-X5 in simulation.
Published something on ARX hardware? Send the link to info@arx-global.us and we will add it to the research page.
Sources